HST DatasetV3
Synthetic HST rendezvous imagery — scenario reference
V3 is an evaluation dataset. It holds high-fidelity rendezvous and proximity-operations geometry for testing pose models, and is not intended for training — train on DLVS3_HST_V1 and V2, which were built for that. 39 scenario sequences are delivered, numbered 01–29 and 31–40; scenario 30 was not generated. Each sequence is rendered from a stereo pair, centre and right, offset by a 0.4 m baseline and sharing one chaser trajectory and one set of epochs.
Scenarios
filter above, hover for a preview, select for the full sheetTrajectory
Regime
Target attitude
Camera
Body
39 of 39 shown
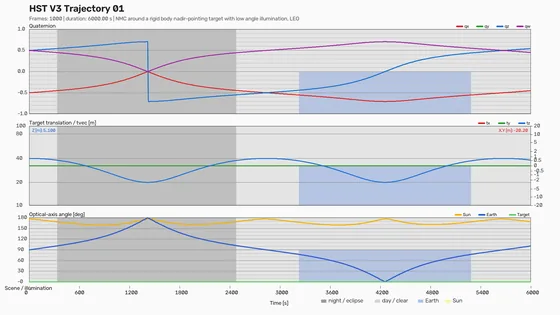 01
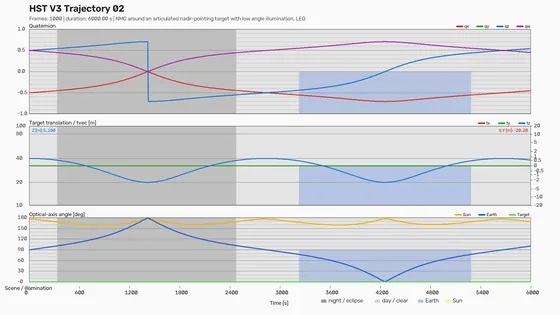 02
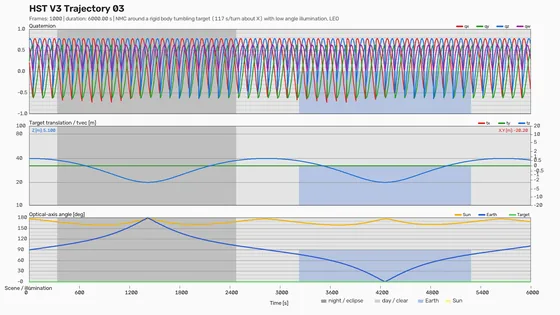 03
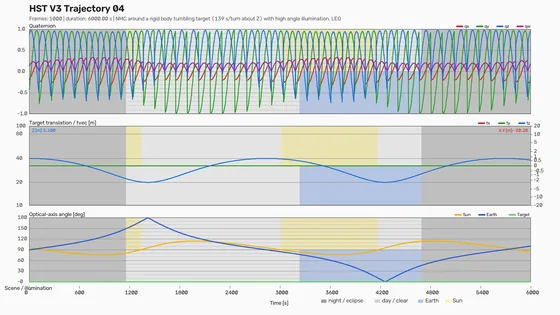 04
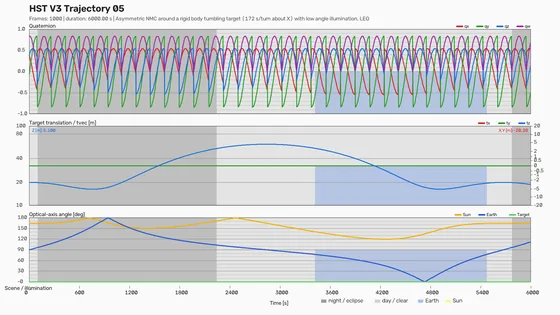 05
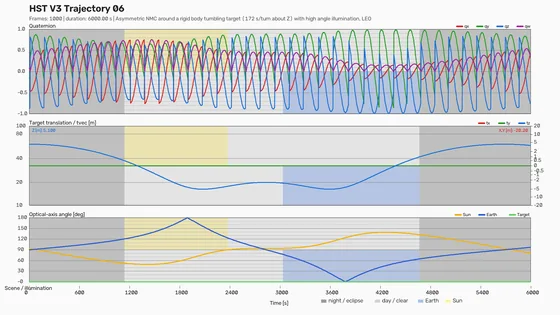 06
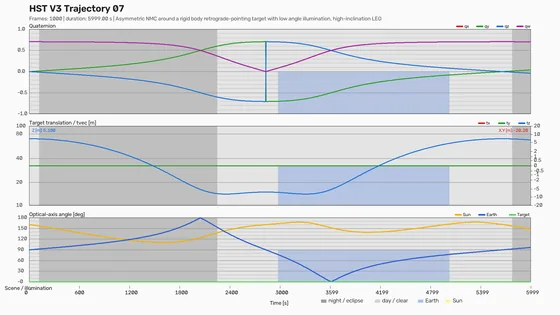 07
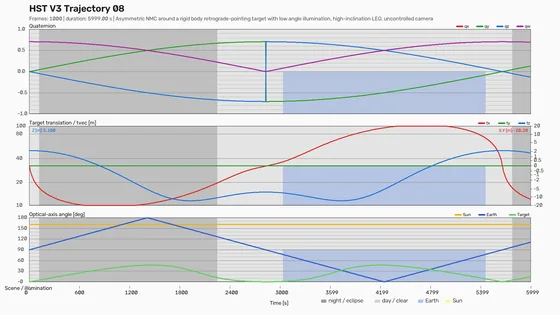 08
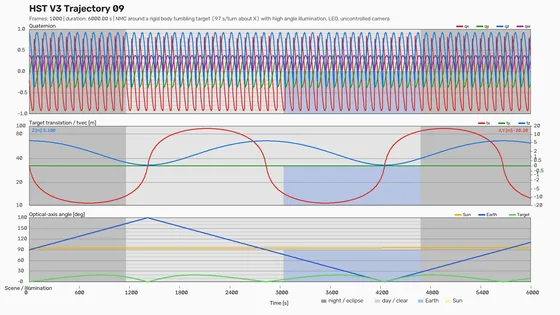 09
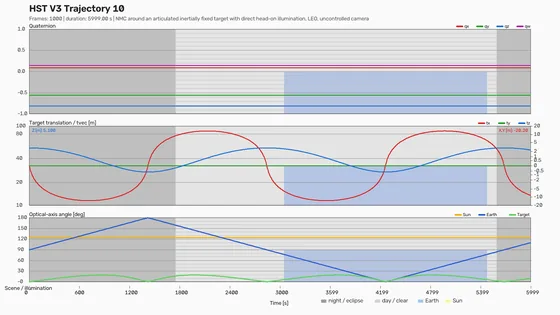 10
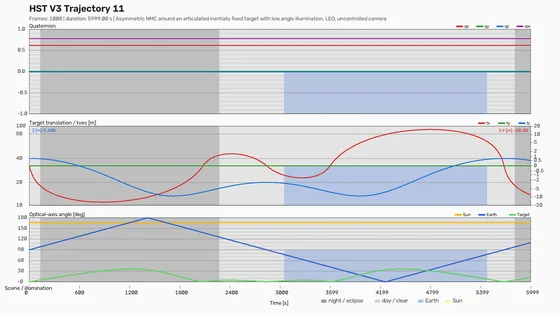 11
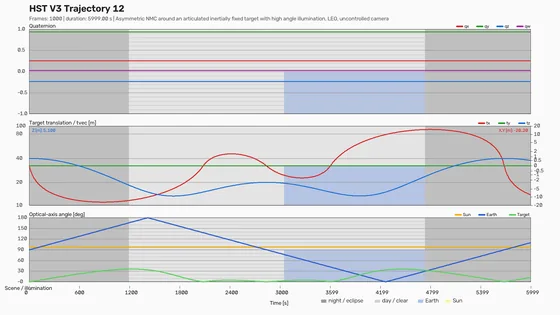 12
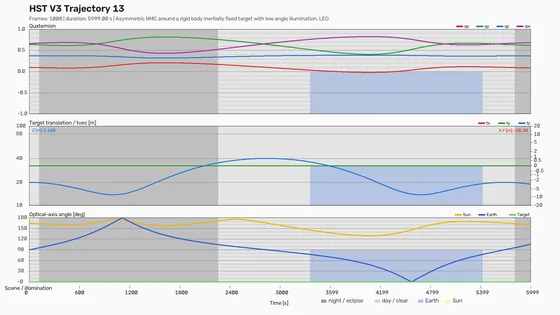 13
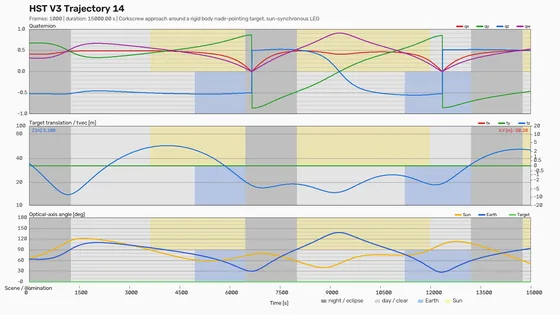 14
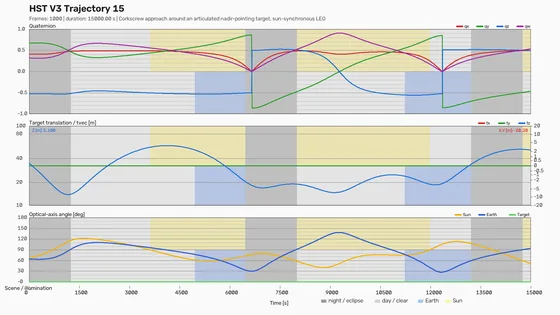 15
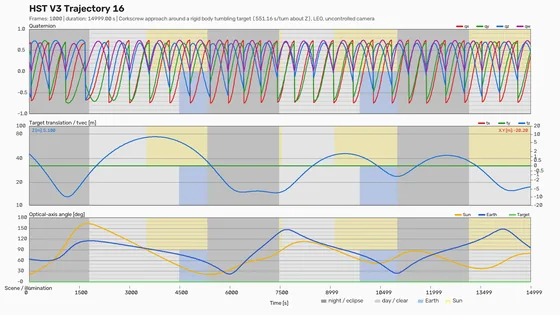 16
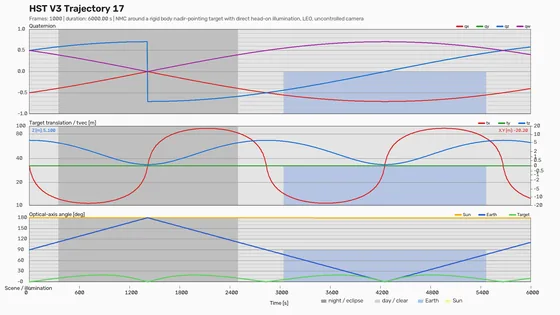 17
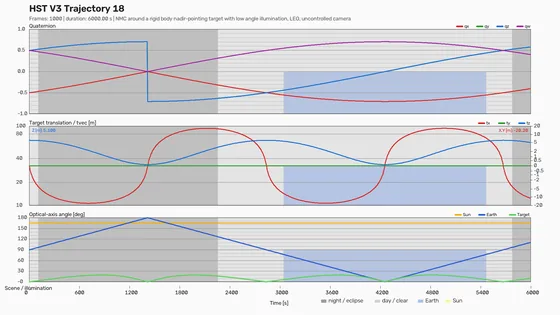 18
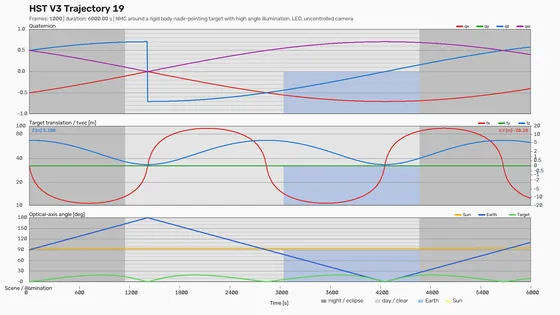 19
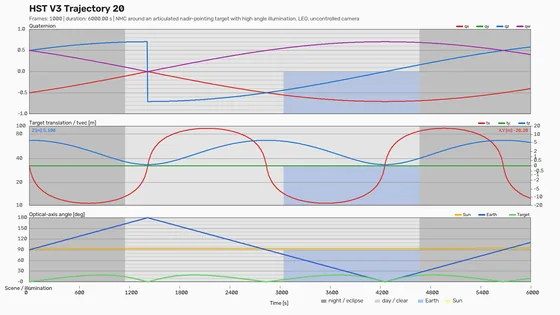 20
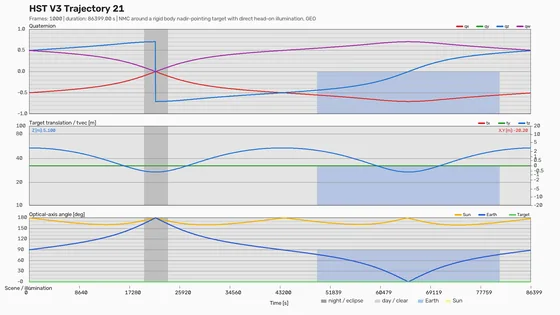 21
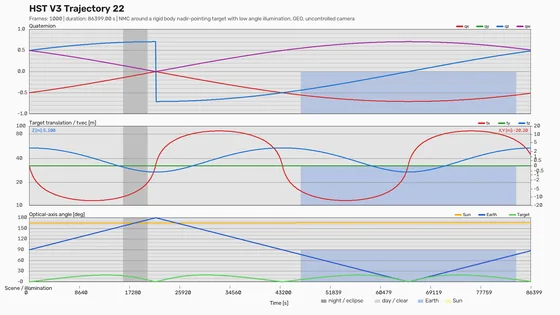 22
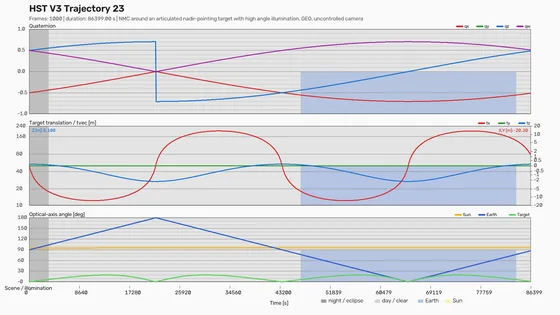 23
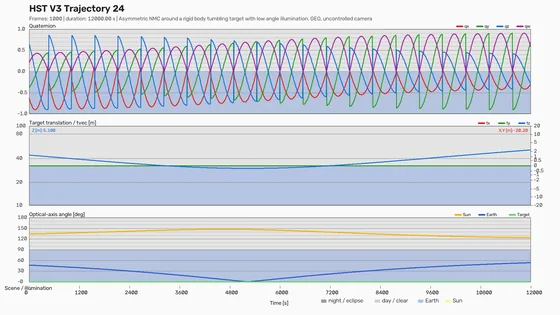 24
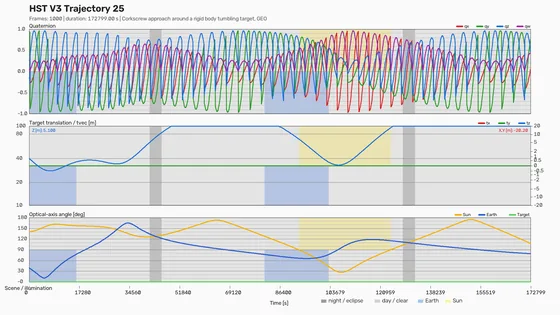 25
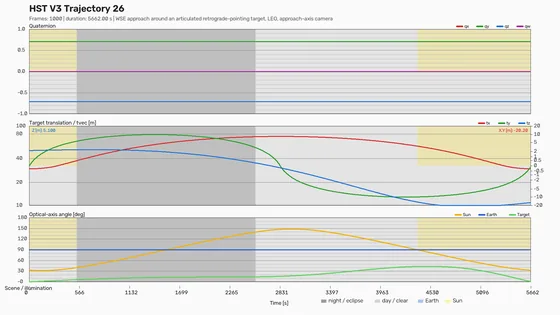 26
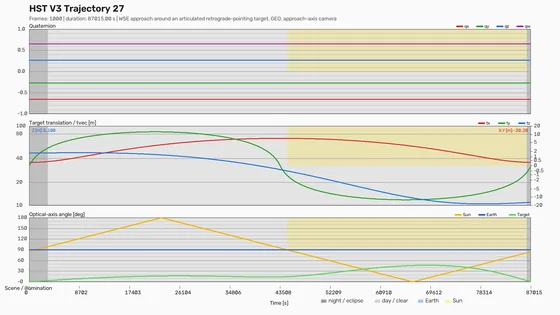 27
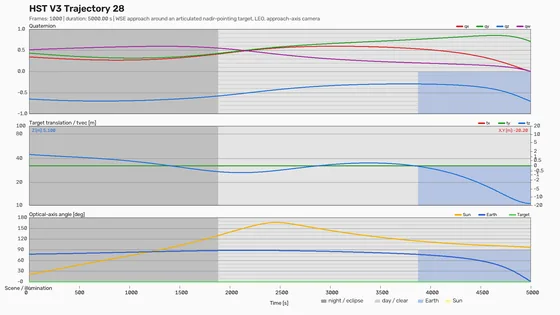 28
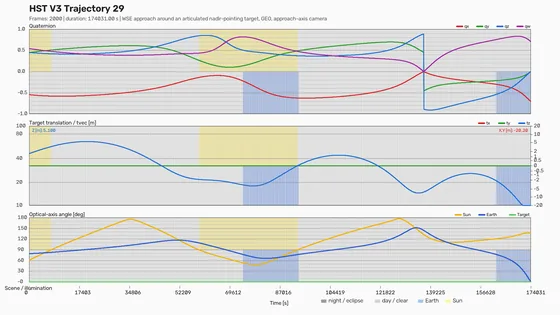 29
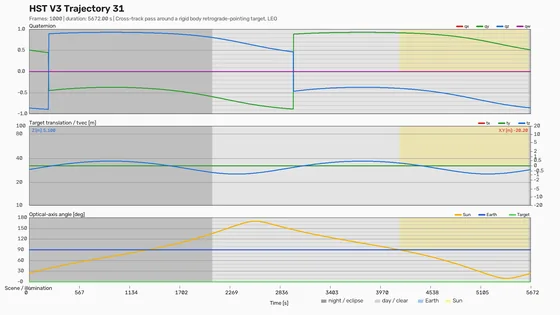 31
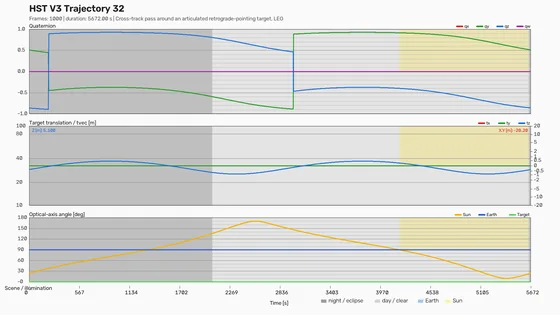 32
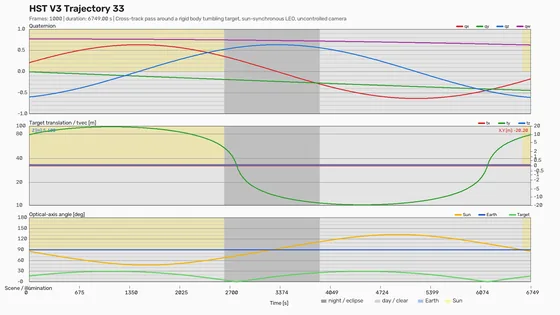 33
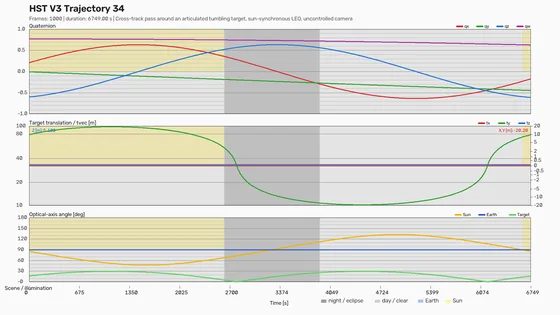 34
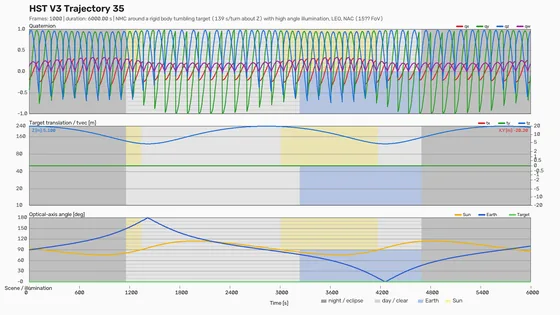 35
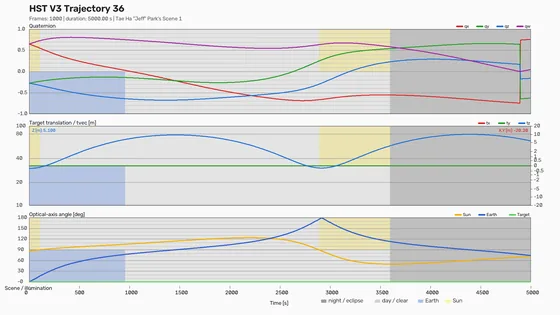 36
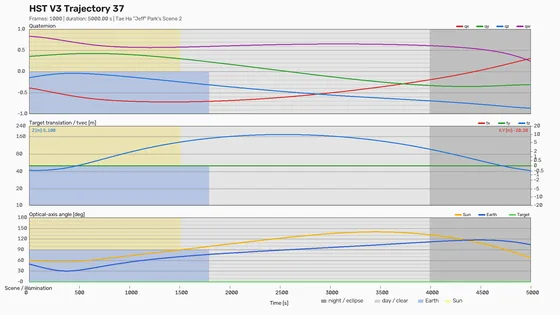 37
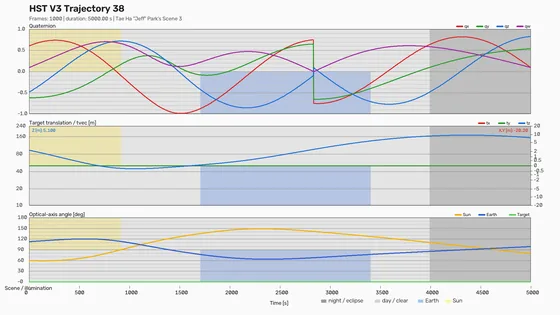 38
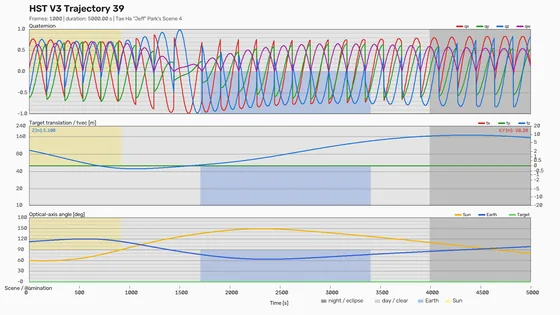 39
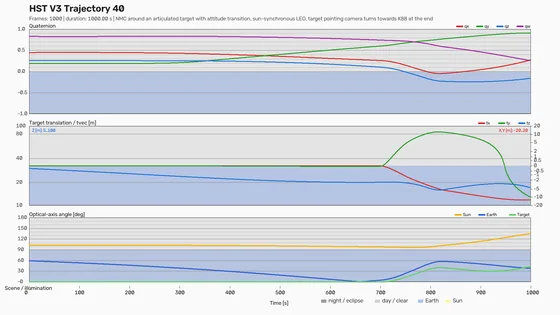 40
| No. | Description | Trajectory | Target attitude | Camera | Regime | Body | H·FoV | Frames | Step [s] | Duration | Start epoch (UTC) |
|---|---|---|---|---|---|---|---|---|---|---|---|
| 01 | NMC around a rigid body nadir-pointing target with low angle illumination, LEO | NMC | Nadir | tracking | LEO | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-04-29 05:58:00 |
| 02 | NMC around an articulated nadir-pointing target with low angle illumination, LEO | NMC | Nadir | tracking | LEO | articulated | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-04-29 05:58:00 |
| 03 | NMC around a rigid body tumbling target (117 s/turn about X) with low angle illumination, LEO | NMC | Tumbling | tracking | LEO | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-04-29 05:58:00 |
| 04 | NMC around a rigid body tumbling target (139 s/turn about Z) with high angle illumination, LEO | NMC | Tumbling | tracking | LEO | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-04-29 06:20:00 |
| 05 | Asymmetric NMC around a rigid body tumbling target (172 s/turn about X) with low angle illumination, LEO | NMC | Tumbling | tracking | LEO | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-06-18 16:56:00 |
| 06 | Asymmetric NMC around a rigid body tumbling target (172 s/turn about Z) with high angle illumination, LEO | NMC | Tumbling | tracking | LEO | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-05-14 20:40:00 |
| 07 | Asymmetric NMC around a rigid body retrograde-pointing target with low angle illumination, high-inclination LEO | NMC | Retrograde | tracking | LEO high-i | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-12-07 18:03:00 |
| 08 | Asymmetric NMC around a rigid body retrograde-pointing target with low angle illumination, high-inclination LEO, uncontrolled camera | NMC | Retrograde | held / drifting | LEO high-i | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-12-07 18:03:00 |
| 09 | NMC around a rigid body tumbling target (97 s/turn about X) with high angle illumination, LEO, uncontrolled camera | NMC | Tumbling | held / drifting | LEO | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-06-28 06:43:00 |
| 10 | NMC around an articulated inertially fixed target with direct head-on illumination, LEO, uncontrolled camera | NMC | Inertially fixed | held / drifting | LEO | articulated | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-02-04 00:59:00 |
| 11 | Asymmetric NMC around an articulated inertially fixed target with low angle illumination, LEO, uncontrolled camera | NMC | Triad | held / drifting | LEO | articulated | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-02-18 06:39:00 |
| 12 | Asymmetric NMC around an articulated inertially fixed target with high angle illumination, LEO, uncontrolled camera | NMC | Inertially fixed | held / drifting | LEO | articulated | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-02-18 06:57:00 |
| 13 | Asymmetric NMC around a rigid body inertially fixed target with low angle illumination, LEO | NMC | Inertially fixed | tracking | LEO | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-01-04 23:22:00 |
| 14 | Corkscrew approach around a rigid body nadir-pointing target, sun-synchronous LEO | Corkscrew | Nadir | tracking | SSO 66° | rigid | 90° | 1000 | 15 | 4 h 10 min 0 s | 2025-09-29 00:00:00 |
| 15 | Corkscrew approach around an articulated nadir-pointing target, sun-synchronous LEO | Corkscrew | Nadir | tracking | SSO 66° | articulated | 90° | 1000 | 15 | 4 h 10 min 0 s | 2025-09-29 00:00:00 |
| 16 | Corkscrew approach around a rigid body tumbling target (551.16 s/turn about Z), LEO | Corkscrew | Tumbling | tracking | LEO | rigid | 90° | 1000 | 15 | 4 h 10 min 0 s | 2025-03-10 07:00:00 |
| 17 | NMC around a rigid body nadir-pointing target with direct head-on illumination, LEO, uncontrolled camera | NMC | Nadir | held / drifting | LEO | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-08-01 17:34:30 |
| 18 | NMC around a rigid body nadir-pointing target with low angle illumination, LEO, uncontrolled camera | NMC | Nadir | held / drifting | LEO | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-08-01 17:38:30 |
| 19 | NMC around a rigid body nadir-pointing target with high angle illumination, LEO, uncontrolled camera | NMC | Nadir | held / drifting | LEO | rigid | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-08-01 17:57:00 |
| 20 | NMC around an articulated nadir-pointing target with high angle illumination, LEO, uncontrolled camera | NMC | Nadir | held / drifting | LEO | articulated | 90° | 1000 | 6 | 1 h 40 min 0 s | 2025-08-01 17:57:00 |
| 21 | NMC around a rigid body nadir-pointing target with direct head-on illumination, GEO | NMC | Nadir | tracking | GEO | rigid | 90° | 1000 | 86.4 | 24 h 0 min 0 s | 2025-09-02 10:13:00 |
| 22 | NMC around a rigid body nadir-pointing target with low angle illumination, GEO, uncontrolled camera | NMC | Nadir | held / drifting | GEO | rigid | 90° | 1000 | 86.4 | 24 h 0 min 0 s | 2025-09-02 11:13:00 |
| 23 | NMC around an articulated nadir-pointing target with high angle illumination, GEO, uncontrolled camera | NMC | Nadir | held / drifting | GEO | articulated | 90° | 1000 | 86.4 | 24 h 0 min 0 s | 2025-09-02 15:56:00 |
| 24 | Natural-phasing approach around a rigid body tumbling target (556.66 s/turn about X) with low angle illumination, GEO | Nat. phasing | Tumbling | tracking | GEO | rigid | 90° | 1000 | 12 | 3 h 20 min 0 s | 2025-09-02 00:30:00 |
| 25 | Corkscrew approach around a rigid body tumbling target (3611.03 s/turn about Z), GEO | Corkscrew | Tumbling | tracking | GEO | rigid | 90° | 1000 | 172.8 | 48 h 0 min 0 s | 2025-09-02 04:13:00 |
| 26 | WSE approach around an articulated retrograde-pointing target, LEO, approach-axis camera | WSE approach | Retrograde | approach axis | LEO | articulated | 90° | 1000 | 5.6632 | 1 h 34 min 23 s | 2025-07-24 03:38:00 |
| 27 | WSE approach around an articulated retrograde-pointing target, GEO, approach-axis camera | WSE approach | Retrograde | approach axis | GEO | articulated | 90° | 1000 | 87.0157 | 24 h 10 min 16 s | 2025-09-08 17:24:00 |
| 28 | WSE approach around an articulated nadir-pointing target, LEO | WSE approach | Nadir | tracking | LEO | articulated | 90° | 1000 | 5 | 1 h 23 min 20 s | 2025-04-22 07:23:00 |
| 29 | WSE approach around an articulated nadir-pointing target, GEO | WSE approach | Nadir | tracking | GEO | articulated | 90° | 2000 | 87.0157 | 48 h 20 min 31 s | 2025-12-03 23:21:00 |
| 31 | Cross-track pass around a rigid body retrograde-pointing target, LEO | Cross-track | Retrograde | tracking | LEO | rigid | 90° | 1000 | 5.6727 | 1 h 34 min 33 s | 2025-02-28 01:19:00 |
| 32 | Cross-track pass around an articulated retrograde-pointing target, LEO | Cross-track | Retrograde | tracking | LEO | articulated | 90° | 1000 | 5.6727 | 1 h 34 min 33 s | 2025-02-28 01:19:00 |
| 33 | Cross-track pass around a rigid body tumbling target (8377.58 s/turn about X), sun-synchronous LEO, velocity-fixed camera | Cross-track | Tumbling | anti-velocity | SSO 66° | rigid | 90° | 1000 | 6.75 | 1 h 52 min 30 s | 2025-01-05 19:15:00 |
| 34 | Cross-track pass around an articulated tumbling target (8377.58 s/turn about X), sun-synchronous LEO, velocity-fixed camera | Cross-track | Tumbling | anti-velocity | SSO 66° | articulated | 90° | 1000 | 6.75 | 1 h 52 min 30 s | 2025-01-05 19:15:00 |
| 35 | NMC around a rigid body tumbling target (139 s/turn about Z) with high angle illumination, LEO, NAC camera (15° horizontal FoV) | NMC | Tumbling | tracking | LEO | rigid | 15° | 1000 | 6 | 1 h 40 min 0 s | 2025-04-29 06:20:00 |
| 36 | Customer-supplied trajectory (Park Scene 1) around an articulated target, 35.27° horizontal FoV | Customer CSV | — | tracking | — | articulated | 35.27° | 1000 | 5 | 1 h 23 min 20 s | 2024-09-01 00:00:00 |
| 37 | Customer-supplied trajectory (Park Scene 2) around an articulated target, 35.27° horizontal FoV | Customer CSV | — | tracking | — | articulated | 35.27° | 1000 | 5 | 1 h 23 min 20 s | 2024-09-01 00:00:00 |
| 38 | Customer-supplied trajectory (Park Scene 3) around a rigid body target, 35.27° horizontal FoV | Customer CSV | — | tracking | — | rigid | 35.27° | 1000 | 5 | 1 h 23 min 20 s | 2024-09-01 00:00:00 |
| 39 | Customer-supplied trajectory (Park Scene 4) around a rigid body target, 35.27° horizontal FoV | Customer CSV | — | tracking | — | rigid | 35.27° | 1000 | 5 | 1 h 23 min 20 s | 2024-09-01 00:00:00 |
| 40 | NMC around an articulated target with a GN-z11 to K88 attitude transition, sun-synchronous LEO, camera slews from the target to Piszkéstető K88 | NMC | Sequenced | sequenced | SSO | articulated | 90° | 1000 | 1 | 16 min 40 s | 2025-08-26 16:18:05 |
| No scenario matches these filters. | |||||||||||
Reading the columns
Camera
- tracking
- boresight held on the target for the whole run
- held / drifting
- attitude solved once, then frozen — the target drifts across the frame
- approach axis
- boresight fixed to the approach direction
- anti-velocity
- boresight fixed opposite the velocity vector
- sequenced
- pointing changes partway through the run
Illumination class
- 180°
- Sun directly behind the chaser — target fully front lit
- ~165°
- low phase angle
- ~95°
- high phase angle
- unclassified
- the angle sweeps through the run; read it off the card
Regime
- LEO
- Hubble reference orbit, 28.5° inclination
- LEO high-i
- 43° inclination
- SSO 66°
- Sentinel-6MF reference orbit, 66° inclination
- SSO
- sun-synchronous, 98.2° inclination
- GEO
- geostationary
- —
- customer-supplied trajectory, no TLE in the pipeline
Dataset-wide properties
identical unless a sheet says otherwiseImagery
- Resolution
- 1024 × 1024 px
- Pixel aspect
- 1
- Pixel samples
- 32
- Render engine
- xpu
- EXR renders
- multi-layer — camera image, depth, normals, and object masks as cryptomatte layers
- PNG images
- post-processed camera image only, no extra layers
Cameras & intrinsics
- Rig
- stereo — centre + right
- Base distance
- 0.4 m along camera +X (image right) — disparity is horizontal
- Camera axes
- −Z forward · +X right · +Y down
- Origin
- centre camera’s optical centre = chaser position; the right camera is offset 0.4 m from it
- Principal point
- cx = cy = 512, all sequences
Horizontal field of view
| Sequences | H·FoV | fx = fy |
|---|---|---|
| 01–29, 31–34, 40 | 90° | 512.00 |
| 36–39 | 35.27° | 1610.61 |
| 35 (NAC) | 15° | 3889.03 |
// square image, square pixels
// _CameraIntrinsicMatrix.json covers
// the 90° set only
fx = fy = 1024 / (2 · tan(FoV / 2))
cx = cy = 1024 / 2 = 512
World frame
- Frame
- ICRF / J2000 equatorial
- Origin
- the target satellite’s reference point
- Axes
- inertial — not rotated from ICRF
- Distances
- metres
- Angles
- degrees
- Epochs
- UTC
// unsuffixed fields are target centred,
// *PositionICRF fields are Earth centred
XxxPosition = XxxPositionICRF − TargetPositionICRF
Annotations
- Format
- JSON array, one object per frame, ascending FrameIndex
- Granularity
- one file per sequence per camera
- Fields per frame
- 41
- Keypoints
- 37, ordered by name
- Vector3 / Vector2
- { X, Y, Z } / { X, Y }
- Matrix4×4
- { Matrix: [r0..r3], Translation: [tx,ty,tz] }
- Convention
- row-major storage, column-vector maths: p’ = Matrix · [x,y,z,1]ᵀ
- Non-finite values
- the JSON string "NaN", not a number
Delivered directory tree
240,234 filesLayout
exr/
  center/<NN>/output_hstv3_<NN>_<fffffff>.exr
  right/<NN>/output_hstv3_<NN>_right_<fffffff>.exr
meta/
  center/output_hstv3_<NN>_metadata.json
  right/output_hstv3_<NN>_right_metadata.json
png/
  color/center/<NN>/  color/right/<NN>/
  bw/center/<NN>/     bw/right/<NN>/
video/
  color/center/HST_DatasetV3_<NN>_color.mp4
  color/right/HST_DatasetV3_<NN>_color_right.mp4
  bw/center/HST_DatasetV3_<NN>_bw.mp4
  bw/right/HST_DatasetV3_<NN>_bw_right.mp4
File counts
- Sequence directories
- 39 per branch
- EXR renders
- 80,000
- PNG images
- 160,000 (colour + B/W)
- Annotation files
- 78
- Preview videos
- 156
- Frames per camera
- 40,000
- Annotated frames
- 80,000
// shipped alongside the tree
_readme.txt
_CameraIntrinsicMatrix.json
_HST_Topology.json
_HST_Component_Hierarchy.txt
Per-frame annotation fields
41 fields, in file order| Group | Fields | Reading them |
|---|---|---|
| Frame identity | FrameIndex · ImagePath · Epoch | ImagePath names the EXR render, not the PNG. Epochs are UTC. |
| Look angles | SunToCameraAngle · EarthToCameraAngle · TargetToCameraAngle · IsSunOcculted | Measured from the chaser body front axis, not the render camera — so the target angle is not exactly 0° for the offset right camera, which views the target from 0.4 m to the side. 180° means the body is directly behind the camera. |
| Positions — target centred | SunPosition · EarthPosition · MoonPosition · ChaserPosition · TargetPosition | TargetPosition is always (0, 0, 0) — it is the world origin. Metres. |
| Positions — Earth centred (ICRF) | SunPositionICRF · EarthPositionICRF · MoonPositionICRF · ChaserPositionICRF · TargetPositionICRF | EarthPositionICRF is always (0, 0, 0). Same axes as the target-centred fields, only the origin differs. |
| Joint angles | ApertureDoorAngle · PV2_SolarPanelAngle · NV2_SolarPanelAngle · PV3_AntennaAngle · PV3_AntennaYawAngle · PV3_AntennaPitchAngle · NV3_AntennaAngle · NV3_AntennaYawAngle · NV3_AntennaPitchAngle | Degrees, per frame. Held constant for the whole run in many sequences. NV2 equals PV2; NV3_AntennaAngle is the negation of PV3_AntennaAngle. |
| Poses (4×4) | CameraTransform · BodyTargetTransform · ApertureDoorTargetTransform · NV2_SolarPanelTargetTransform · PV2_SolarPanelTargetTransform · NV3_AntennaBaseTargetTransform · PV3_AntennaBaseTargetTransform · NV3_AntennaTargetTransform · PV3_AntennaTargetTransform | CameraTransform is world-to-camera. The *TargetTransform matrices are expressed in the _HST_Topology.json model frame, so topology coordinates multiply straight through them. |
| Screen projections | SunCenter · EarthCenter · MoonCenter · TargetCenter · TargetKeypoints · TargetKeypointsWorld | Pixels, 2 decimals, not clipped to the image. The *Center fields are the string "NaN" when the body is behind the camera; keypoints are always numeric. TargetKeypointsWorld is target centred. |
Projecting a world point
// p is already in world coordinates
q = CameraTransform · [p, 1]
skip if q.Z > 0        // behind the camera
x = −q.X / q.Z · 512 + 512
y =  q.Y / q.Z · 512 + 512
Projecting a topology keypoint
// p is local, from _HST_Topology.json
w = TargetTransform · [p, 1]
q = CameraTransform · [w, 1]      // left, not right
x = −q.X / q.Z · 512 + 512
y =  q.Y / q.Z · 512 + 512
Target articulation model
_HST_Topology.json| Component | Axis | Range in V3 | Notes |
|---|---|---|---|
| ApertureDoor | Z | 0° → −112° | Door opening |
| PV2_SolarPanel | Z | −180° → +180° | Hinged solar array |
| NV2_SolarPanel | Z | −180° → +180° | Equal to PV2_SolarPanel |
| PV3_Antenna | Z | 0° → −90° | Base hinge |
| PV3_AntennaYaw | Y | −180° → +180° | Yaw gimbal |
| PV3_AntennaPitch | Z | 0° → +90° | Pitch gimbal |
| NV3_Antenna | Z | 0° → +90° | Negated PV3_Antenna |
| NV3_AntennaYaw | Y | −180° → +180° | Yaw gimbal, independent |
| NV3_AntennaPitch | Z | 0° → −90° | Pitch gimbal, independent |
Recommended use
_readme.txt § 7.0Evaluation protocol
- DLVS3_HST_V1
- training set, rigid target — 640,000 images, first 600,000 train + last 40,000 test
- DLVS3_HST_V2
- training set, articulated target — 320,000 images, first 300,000 train + last 20,000 test
- DLVS3_HST_V3
- test set, 39 RPO trajectories — 40,000 frames per camera, 80,000 with the stereo pair
- Split
- defined for the training sets only; V3 is tested whole
Reporting
- Report on
- the full set, and per sequence wherever possible
- Why per sequence
- each sequence is a distinct RPO scenario; one aggregate number hides exactly the behaviour this set was built to expose
- The two cameras
- they share a trajectory and epochs, so counting them as independent monocular samples overstates the test set — the right camera is the second eye of a 0.4 m-baseline stereo rig, meant to be used with the centre one